Nathan Tsoi
I am a full-stack robotics researcher developing the algorithmic, mathematical, and experimental foundations for coadaptive physical AI. Bridging computer science, engineering, and psychology, my research investigates how autonomous robots can infer the latent, continually evolving internal states of nearby people (such as trust, perceived competence, comfort, and satisfaction) from their behavior and close the loop in robotic decision-making and control. My work combines human-centric simulation and evaluation, spatiotemporal social perception, and coadaptive control across autonomous vehicles, mobile manipulators, quadrupeds, and humanoids.
I am a Postdoctoral Fellow in Computer Science at UT Austin, working with Joydeep Biswas and Peter Stone, and an Assistant Professor of Practice leading the Autonomous Driving research stream in the Freshman Research Initiative. I received my Ph.D. in Computer Science from Yale University advised by Marynel Vázquez, where I introduced open-source simulation platforms, scalable evaluation methodologies, and perception models for Human-Robot Interaction. Previously, I built AI and production software systems as a Research Engineer at the Stanford AI Lab and a Senior Software Engineer at Sequoia Capital.
News
Recent Research
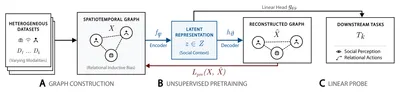
STARS: From Spatiotemporal Dynamics to Social Representations in Human-Robot Interaction
Nathan Tsoi*, Michael J. Munje*, Tejas Oberoi, Rishab Maheshwari, Pengen Zheng, Tanush Chauhan, Peter Stone, and Joydeep Biswas
Proceedings of The 10th Conference on Robot Learning (CoRL)
Fielding socially competent robots requires joint reasoning over spatial information and the social information it can convey, such as group motion and personal space. While current models excel at either spatial reasoning (e.g., modeling physical dy...
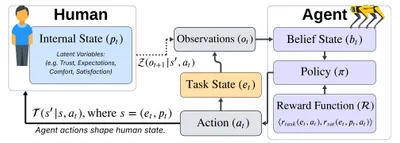
Coadaptive Value Alignment
Nathan Tsoi, Eric Hsiung, Masayuki Yamazaki, Swarat Chaudhuri, Peter Stone, and Joydeep Biswas
Proceedings of the 25th International Conference on Autonomous Agents and Multiagent Systems (AAMAS) Blue Sky Ideas Track
The integration of autonomous agents into human society is a grand challenge for AI. In order to achieve widespread acceptance, agents must conform to the values of people with whom they interact. Current approaches treat the value alignment problem ...
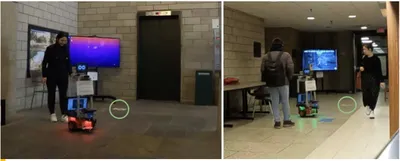
Predicting Human Perceptions of Robot Performance During Navigation Tasks
Qiping Zhang*, Nathan Tsoi*, Mofeed Nagib, Booyeon Choi, Jie Tan, Hao-Tien Lewis Chiang, and Marynel Vázquez
ACM Transactions on Human-Robot Interaction (THRI)
Understanding human perceptions of robot performance is crucial for designing socially intelligent robots that can adapt to human expectations. Current approaches often rely on surveys, which can disrupt ongoing human-robot interactions. As an altern...
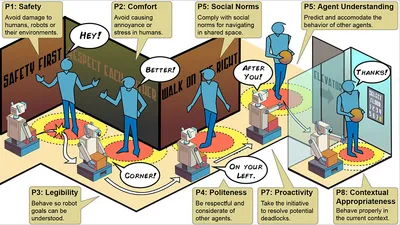
Principles and Guidelines for Evaluating Social Robot Navigation Algorithms
Anthony Francis, Claudia Pérez-D'Arpino, Chengshu Li, Fei Xia, Alexandre Alahi, Rachid Alami, Aniket Bera, Abhijat Biswas, Joydeep Biswas, Rohan Chandra, Hao-Tien Lewis Chiang, Michael Everett, Sehoon Ha, Justin Hart, Jonathan P. How, Haresh Karnan, Tsang-Wei Edward Lee, Luis J. Manso, Reuth Mirsky, Sören Pirk, Phani Teja Singamaneni, Peter Stone, Ada V. Taylor, Peter Trautman, Nathan Tsoi, Marynel Vázquez, Xuesu Xiao, Peng Xu, Naoki Yokoyama, Alexander Toshev, and Roberto Martín-Martín
ACM Transactions on Human-Robot Interaction (THRI)
A major challenge to deploying robots widely is navigation in human-populated environments, commonly referred to as social robot navigation. While the field of social navigation has advanced tremendously in recent years, the fair evaluation of algori...